Temporary Stop
The ego starts at a standstill 15 m short of a stop line that no traffic light governs -- a stop sign's. It has to stop at the line and then go again -- on every such stop line of the map.
# Every case on the map, one run each
uv run scenario --multirun hydra/sweeper=lanelet_constraint \
    scenario=temporary_stop/temporary_stop map=<map>
In the Scenario Editor
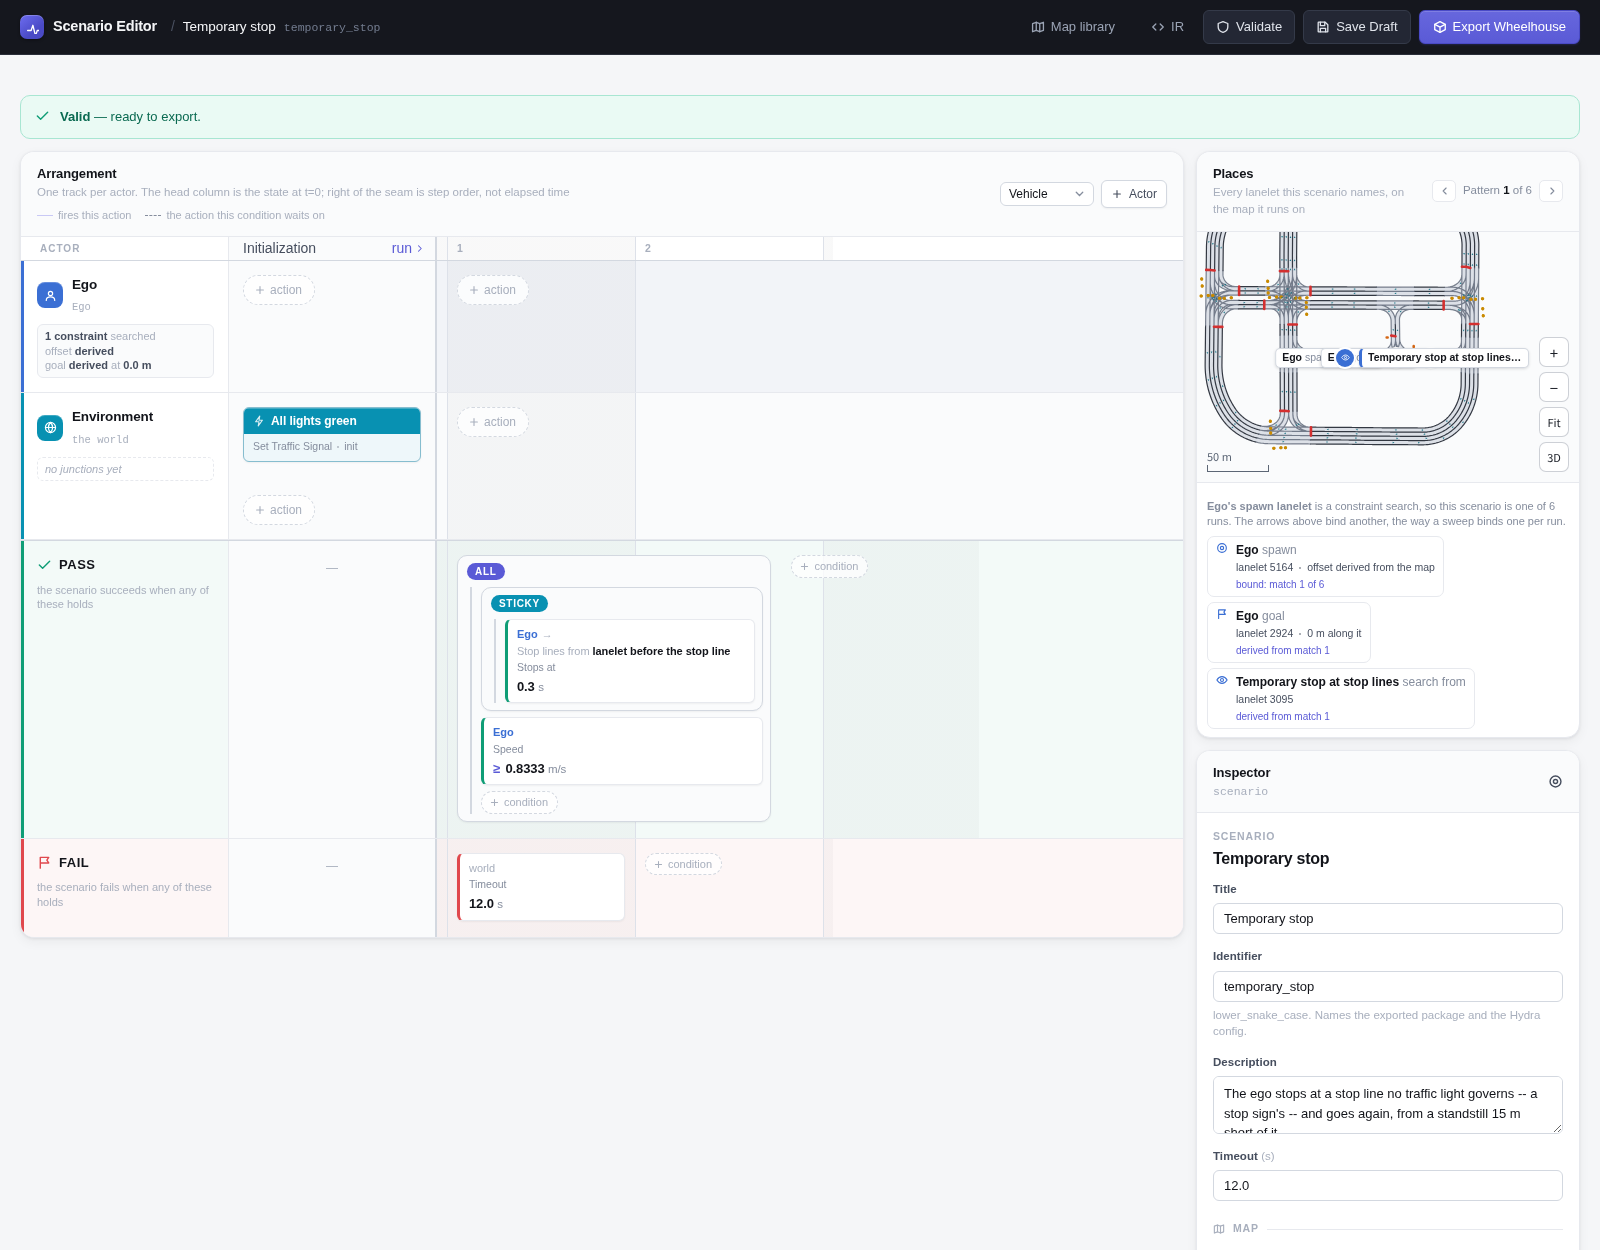
Scenario
| Ego | Constraint search: a lanelet with a stop line that is not a traffic light's, excluding the map's lanelets with no 3D model. Position before stop line: 15 m short of it, on the lanelet before when the line is nearer its lanelet's start than that. Goal from the search: the lanelet after the matched one, past the line. |
| Initialization | Every traffic light green. |
| Pass | The ego has made a temporary stop -- under 0.1 m/s for 0.3 s within 5 m of a stop line -- and is moving at 3 km/h again. The stop lines are read off the map: those of the lanelet the ego starts on, or else of the first step of its successors, up to three steps on, that has any (lanelet before the stop line, from the search). |
| Fail | 12 s pass. |
Parameters
| Parameter | Value |
|---|---|
| Spawn | 15 m before the stop line |
| Ego initial speed | 0 km/h |
| Stopped below | 0.1 m/s |
| Held for | 0.3 s |
| Within | 5 m of the stop line |
| Restart speed | 3 km/h |
| Stop lines searched | the spawn lanelet, then up to 3 steps of its successors |
| Timeout | 12 s |
Result
Town10HD_Opt, the first case: the search matched lanelet 5164 and the ego starts on lanelet 3095, 39.0 m along it. Result: PASSED.